This is Nakamura from LOCAHUN 3D. We took our 3DGS scan of Tokyo's Shibuya scramble crossing straight into NVIDIA Isaac Sim and drove a robot around it. The stage is the real crossing; the robot is Isaac's stock Nova Carter. Here are the results, with the details left out.
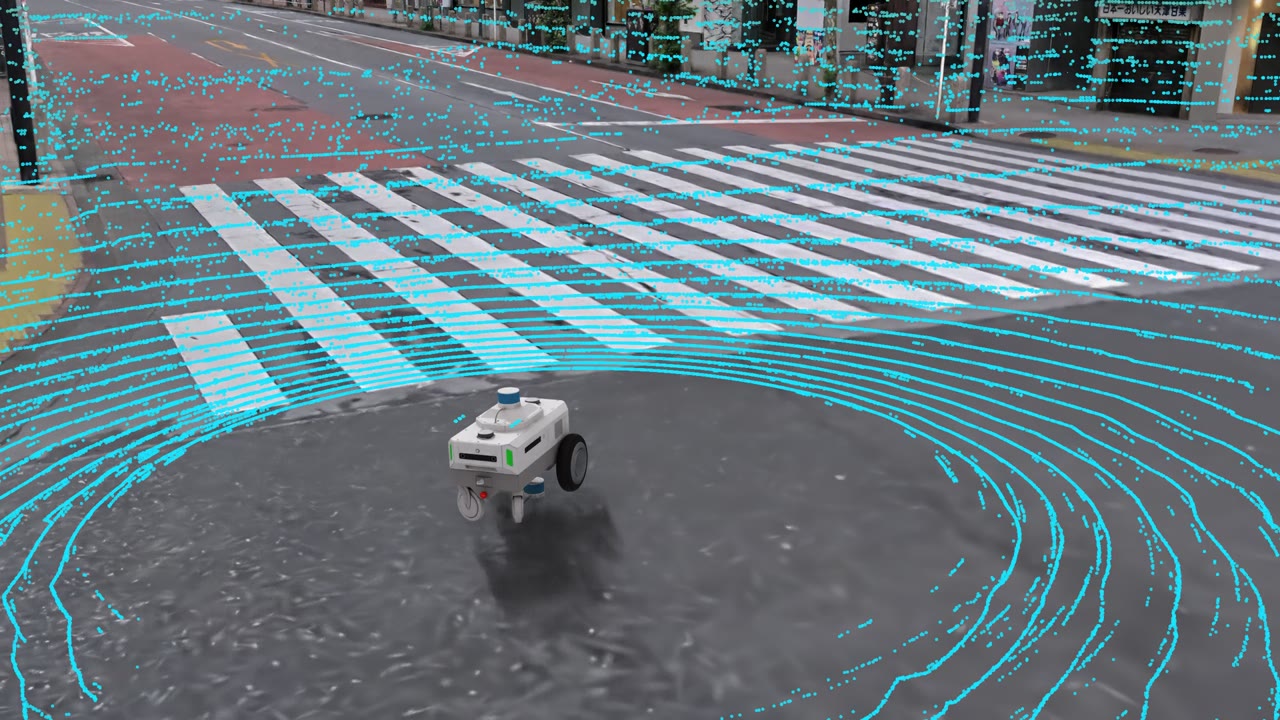
The robot driving through the scanned Shibuya with its LiDAR sweeping.The street you see is the scan exactly as it was captured.
Sweeping the city with LiDAR
The robot crosses the zebra while its LiDAR point cloud traces the street.The camera view and the point cloud are captured together in a single drive.
Moving the time of day to see the shadows
From sunrise to sunset, the shadows of lamp posts, signs and the police box sweep across the crossing.The same place can be shown as a different time of day.
Building a map and driving to a goal
A route is drawn on a map built from the street (top right), and the robot rounds the corner of the police box to reach its goal.Orange is the path actually driven; the red triangle is the current position.
Crossing while watching the signal
A delivery robot leaves the west plaza, waits for the light on the police-box island, and crosses south on the central zebra.It reads both the signal colour and the zebra at its feet from its own camera. It stops on red, and waits for the next green when it judges it cannot get across in time.
Stopping and restarting among pedestrians
The robot moves through stand-in pedestrians (the coloured posts) while watching the space ahead.It stops when something enters that space and sets off again once it clears.
Going to a place named in words
Four destinations from the same start: "the corner of the police box", "the pavement on the south side", "the pavement under the street trees" and "under the chestnut-stand sign".Destinations can be written using real landmarks.
Because a real place comes in at real scale, questions like whether the robot fits through, where it will end up waiting, and where to put a camera can be settled from the picture before anyone goes on site.
SCAN / 3DGS
LOCAHUN 3D scans real places in a form robot development can use
You get the 3DGS exactly as it looks, together with measured geometry, aligned in one coordinate frame. Indoors or out, talk to us from the point of building the environment you will use in Isaac Sim.